Step 1
Match
Find the bay that fits your design, and see what differs.


 Attend our in-person Robotics & Math
FREE workshop
for your child (7-18yrs old) in your City
Reserve a seat today!
(No credit card needed)

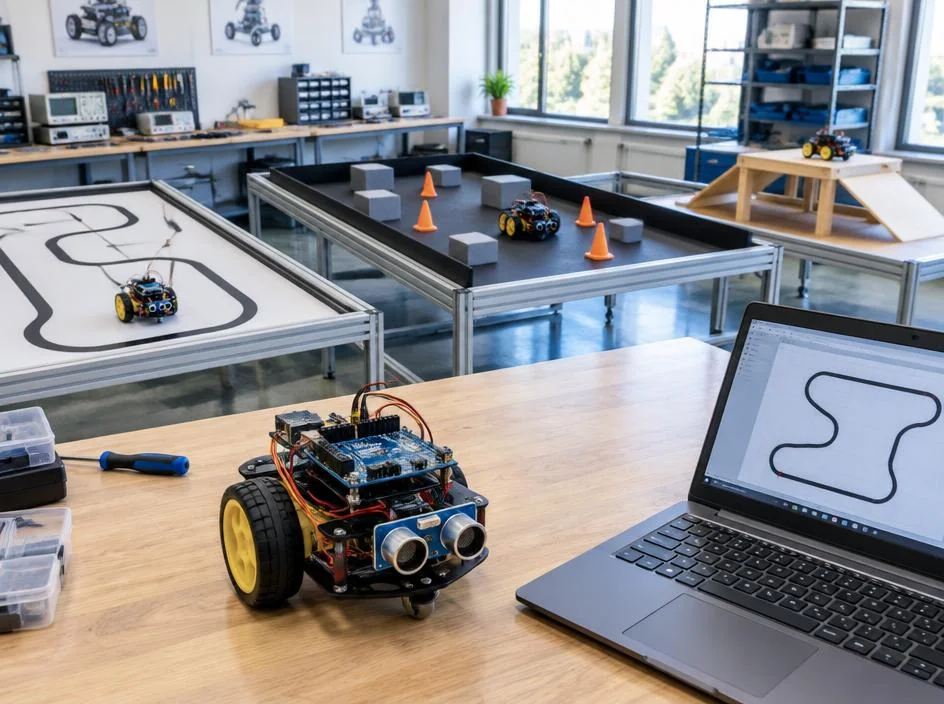
The lab runs the program you proved in MoonVerse on real hardware, then hands back the recording, data and grade.
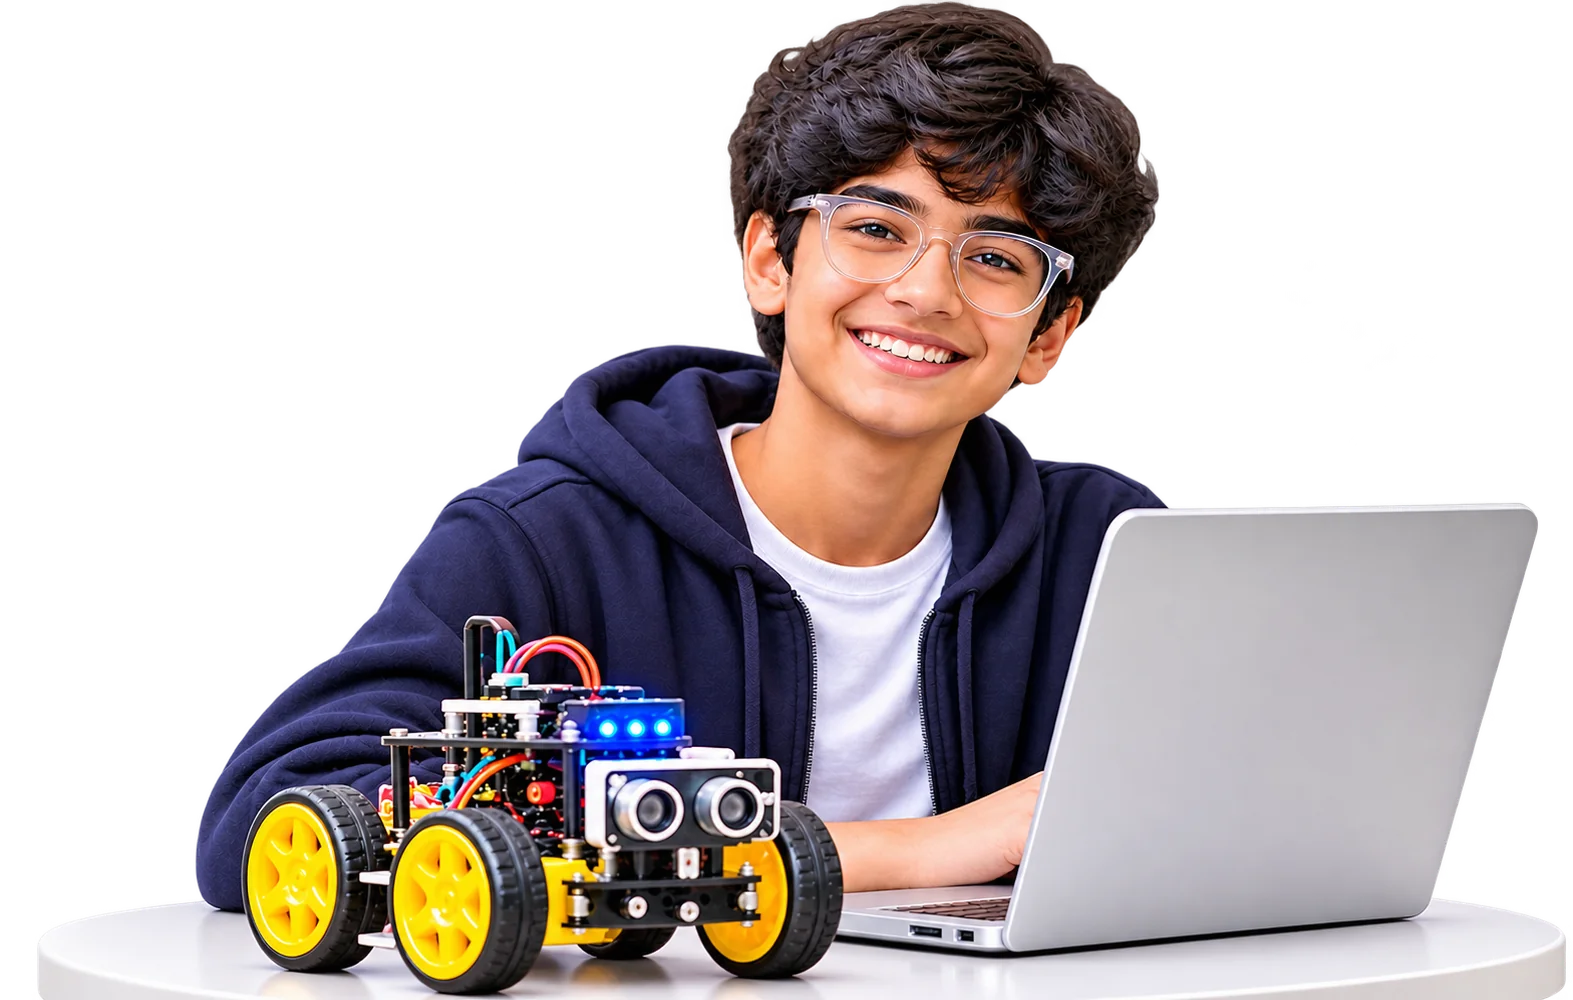
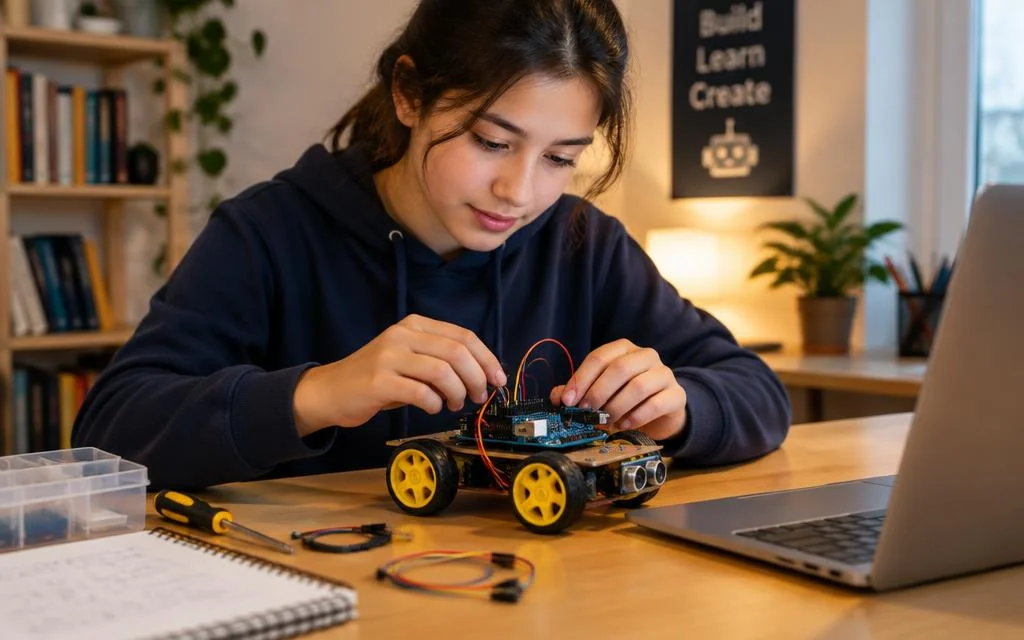
Students experiment with a physical kit at home. The lab is where projects that need high-end robotics get tested.
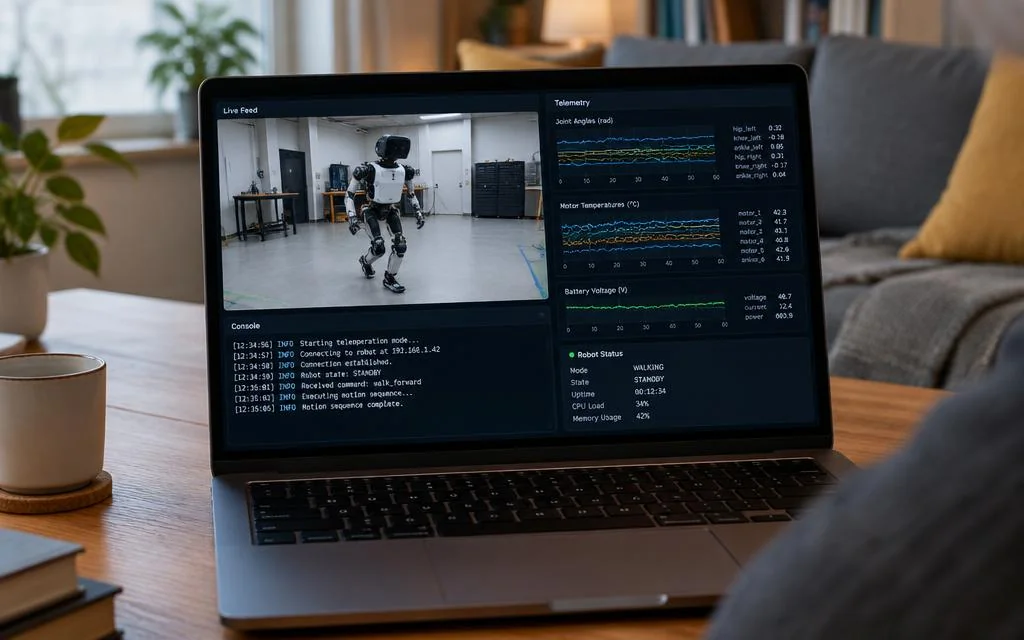
Book a slot and watch it live from anywhere, with the console and telemetry in front of you.
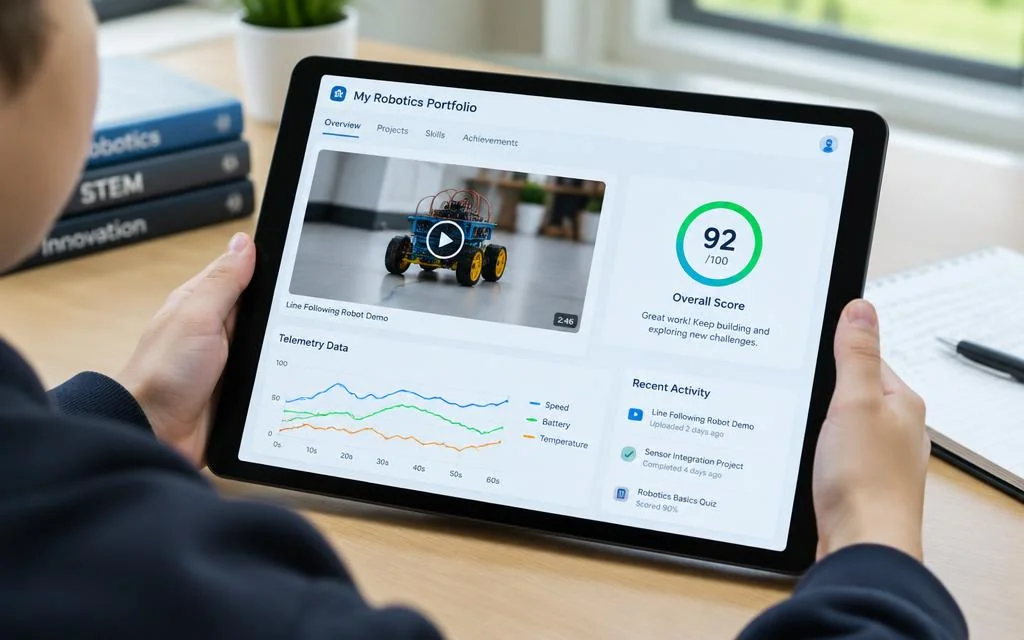
Video, telemetry and score go into your portfolio, graded against your mission.
Twenty-minute slots by default. Longer for slow bays such as the garden, and extendable live.
Find the bay that fits your design, and see what differs.
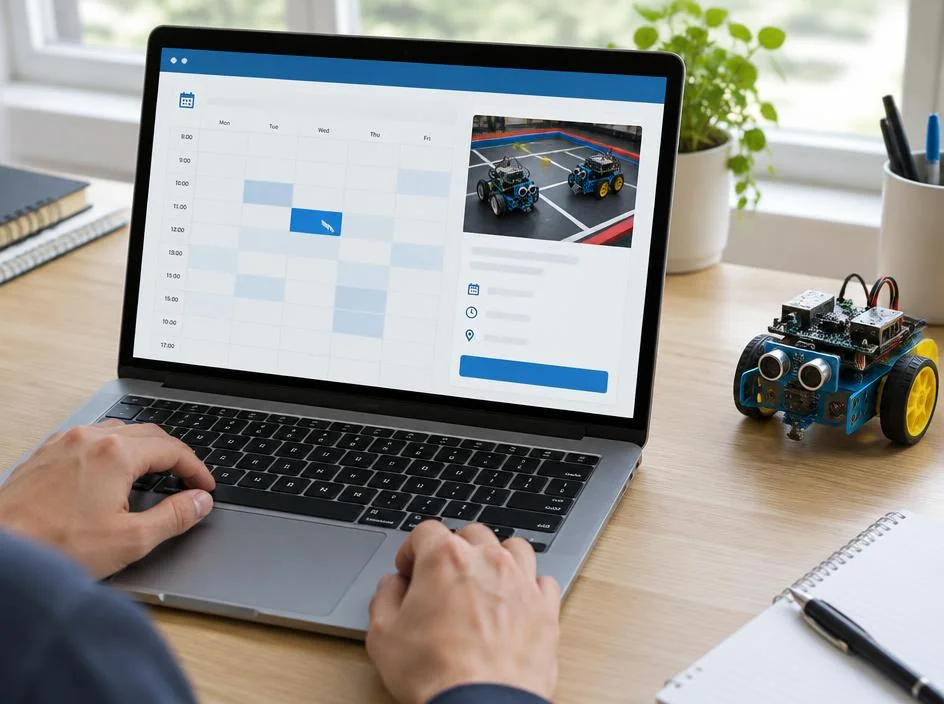
Pick a slot. Game bays hold two seats.
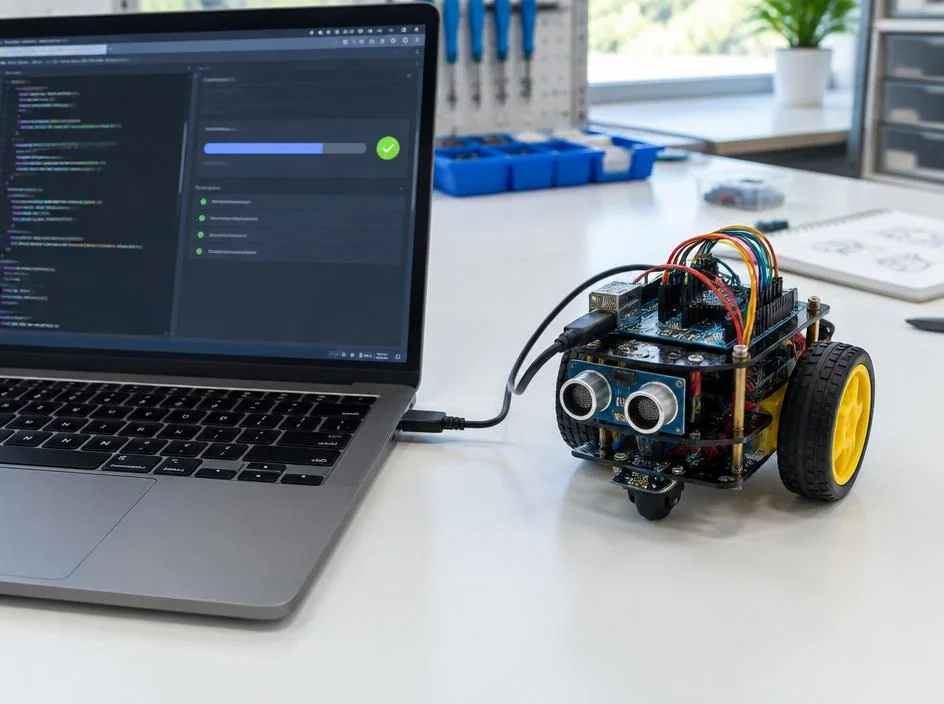
Your program loads unchanged and is checked by hash.
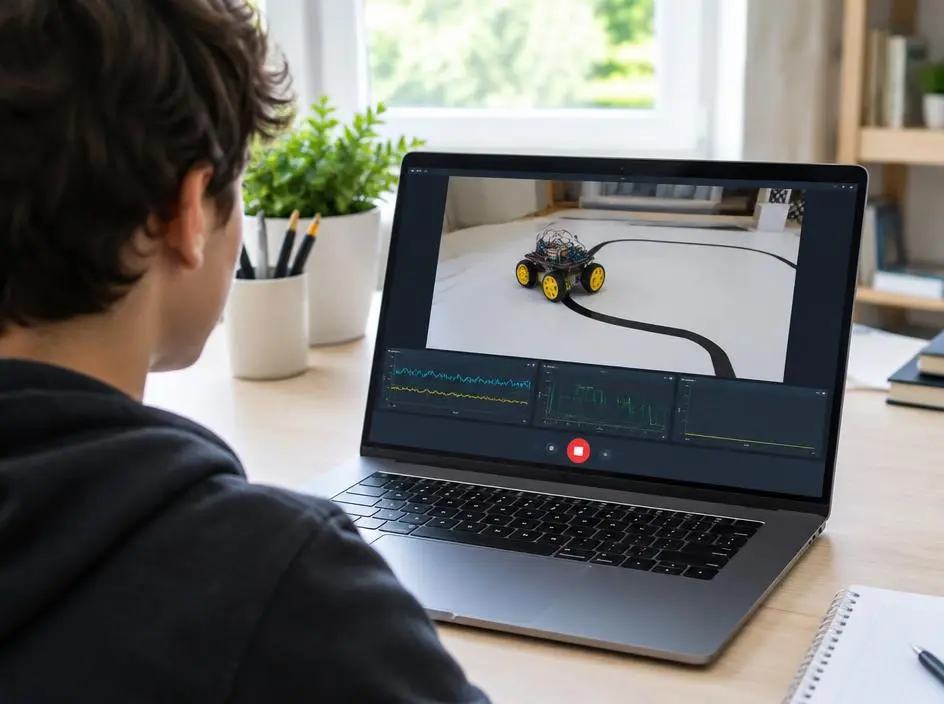
Watch live. Stop, extend or end at any time.
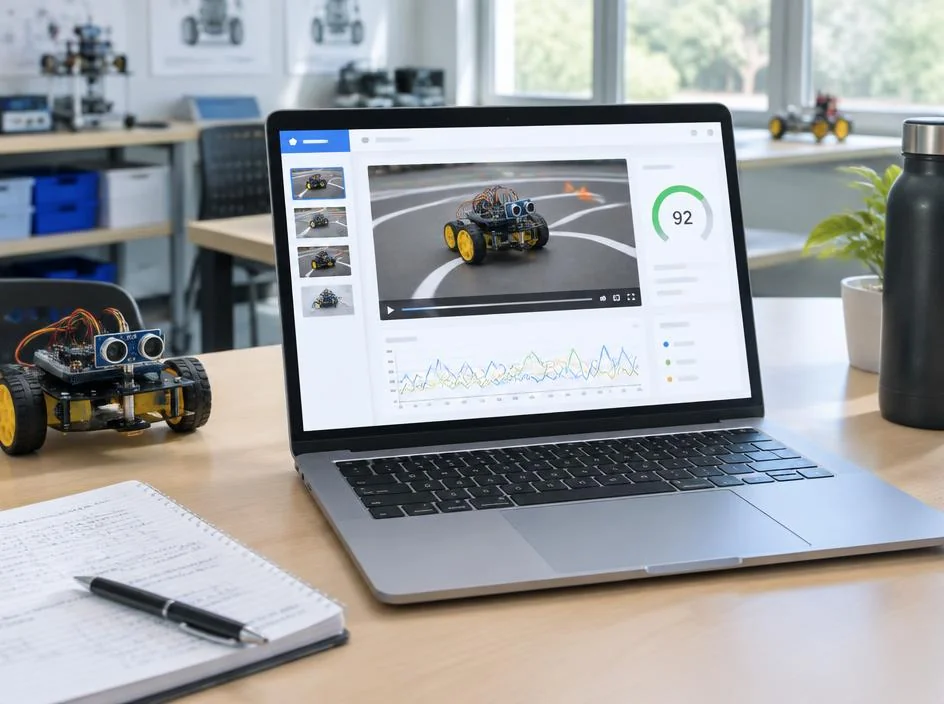
Recordings, data and grade go to your creation record.
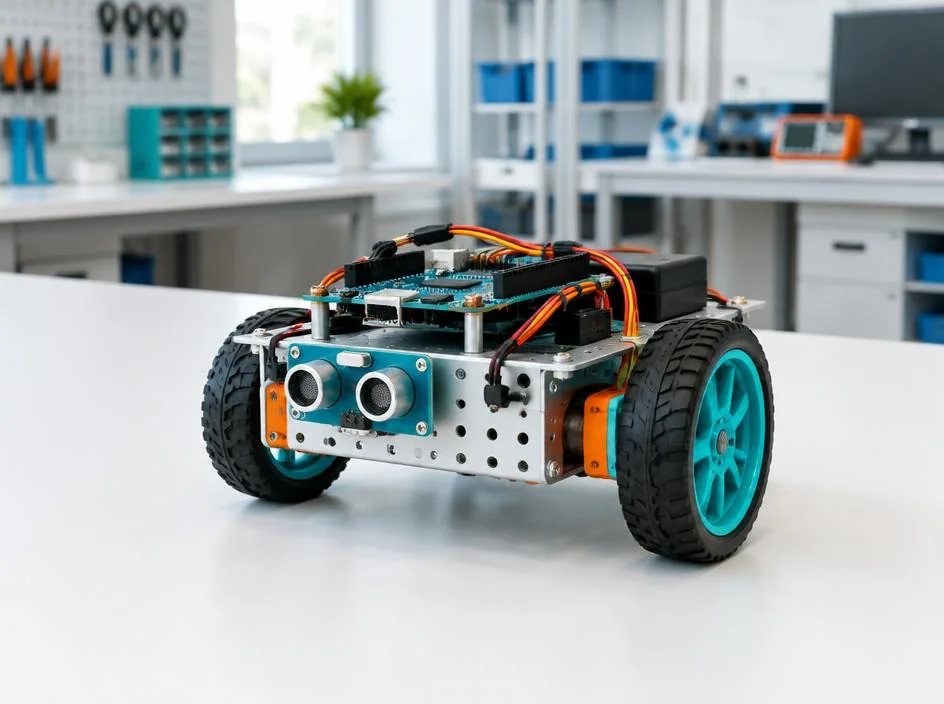
On a micro:bit, Pico or NodeMCU, matched to the target your design uses.
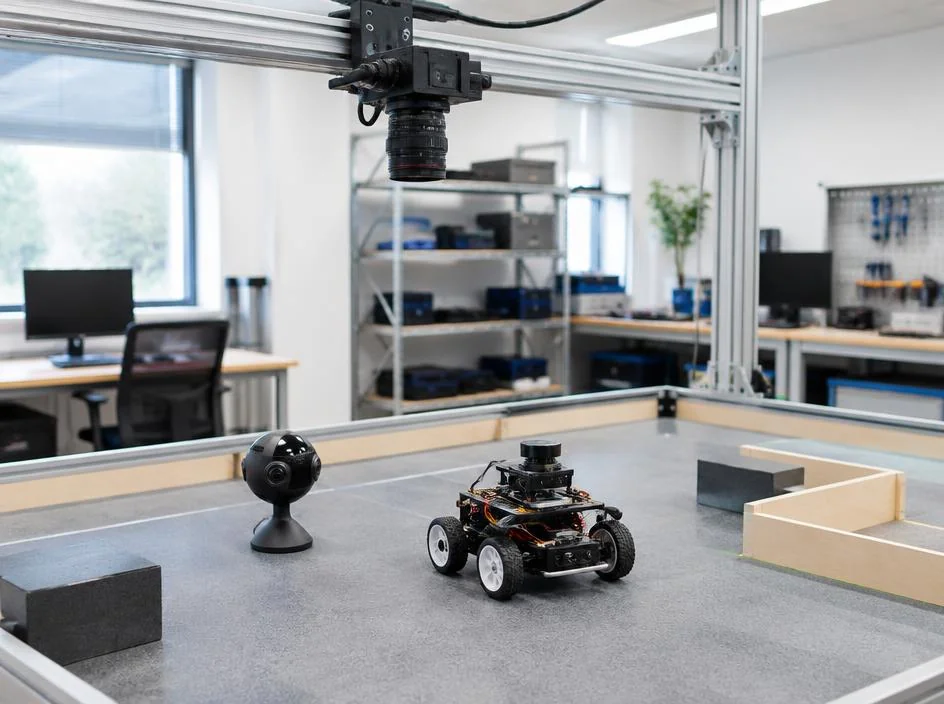
Overhead and 360-degree, streamed live and recorded for every run.
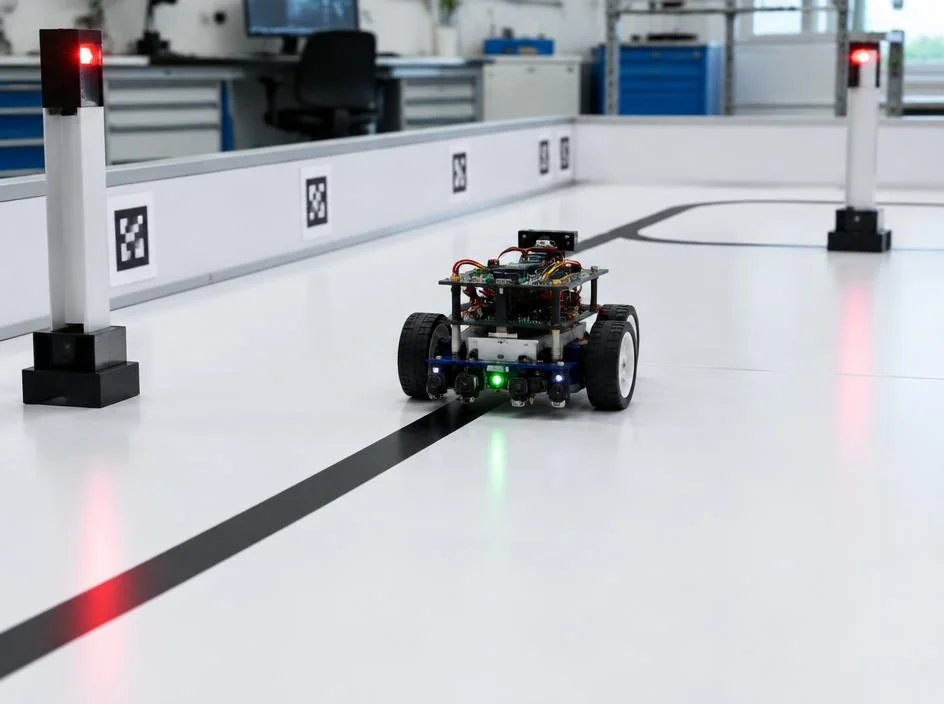
Tags, IR goals and line events. The bay keeps score, not your code.
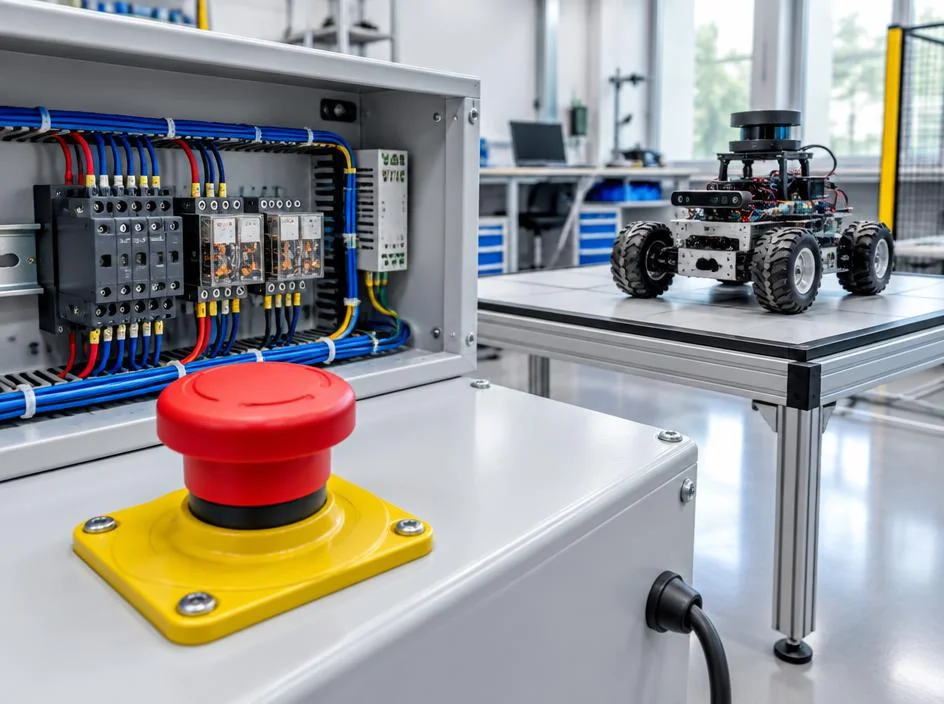
Time limits, a software stop, then a power relay.
Added without changing your design.
Both end the same way: your program, your robot for the session, your record.
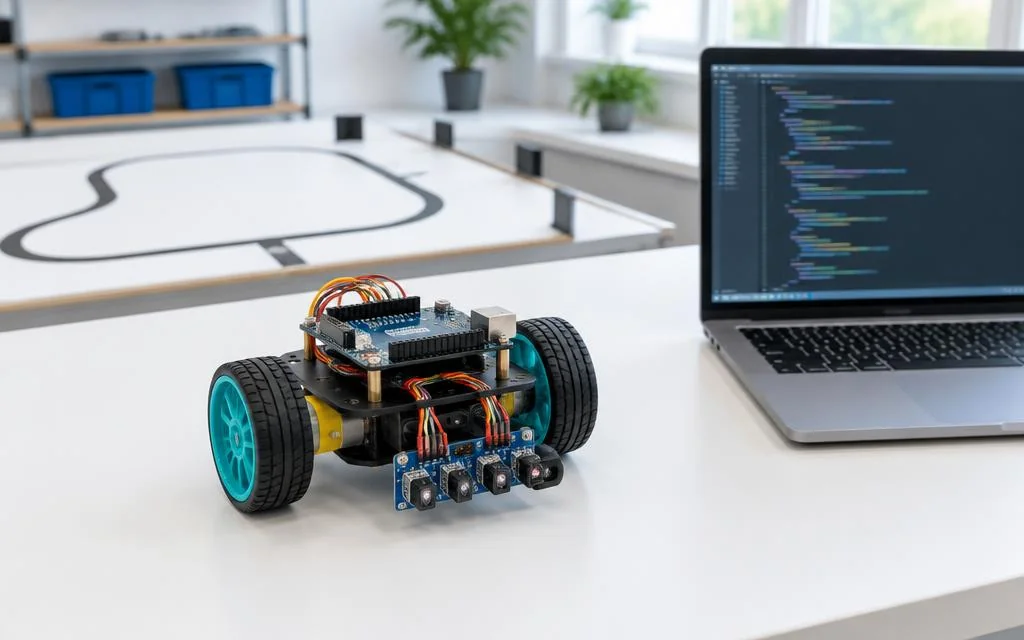
The bay already holds a robot whose capabilities match your design. Your program is deployed unchanged and the robot is yours for the slot.
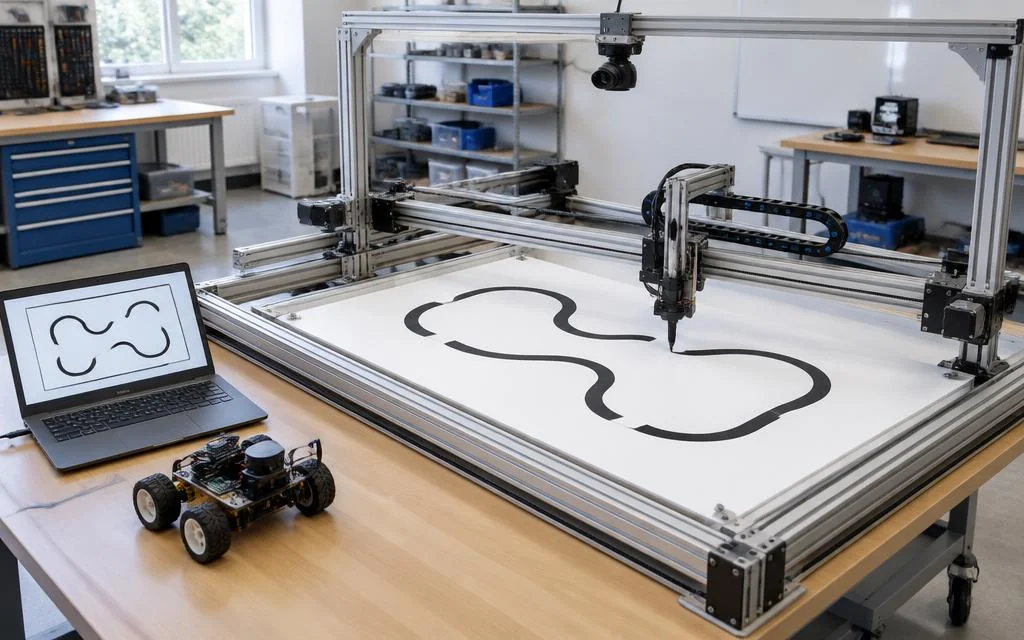
Draw your own track or arena in MoonVerse. The lab's plotter and gantry build it, a camera verifies it against your design, and your layout becomes bookable by anyone.
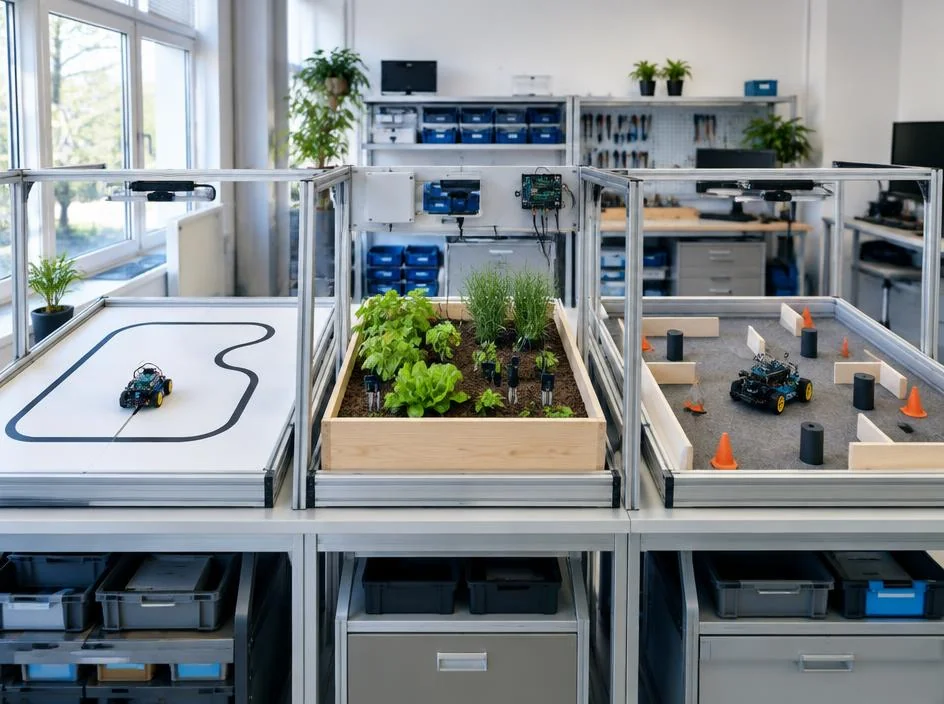
Whatever you design in MoonTinker, the lab can build. We open with these three.
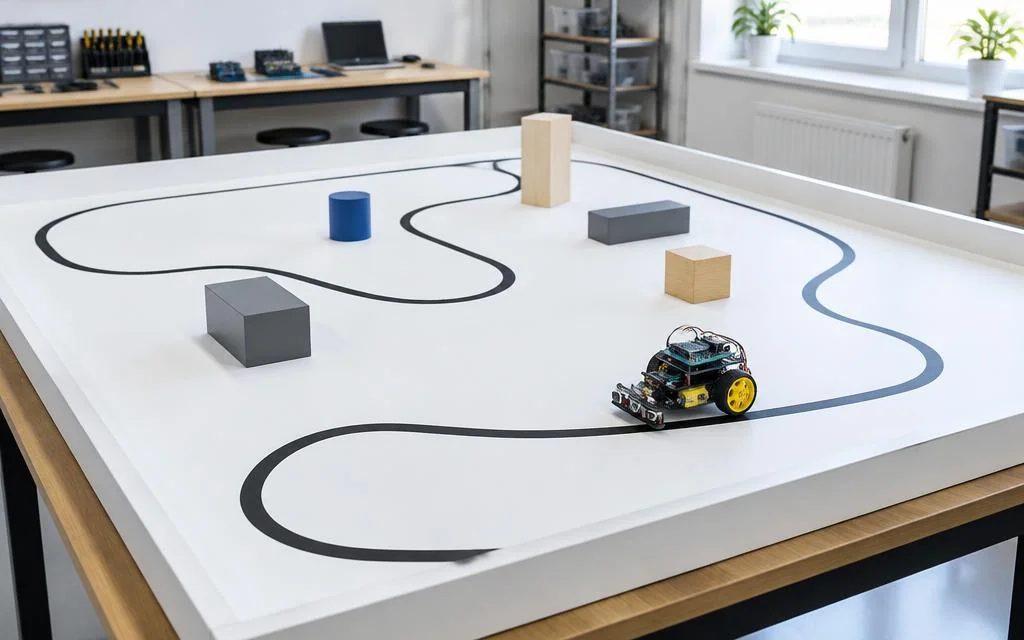
Line-following and obstacle courses on a 1.2 m arena.
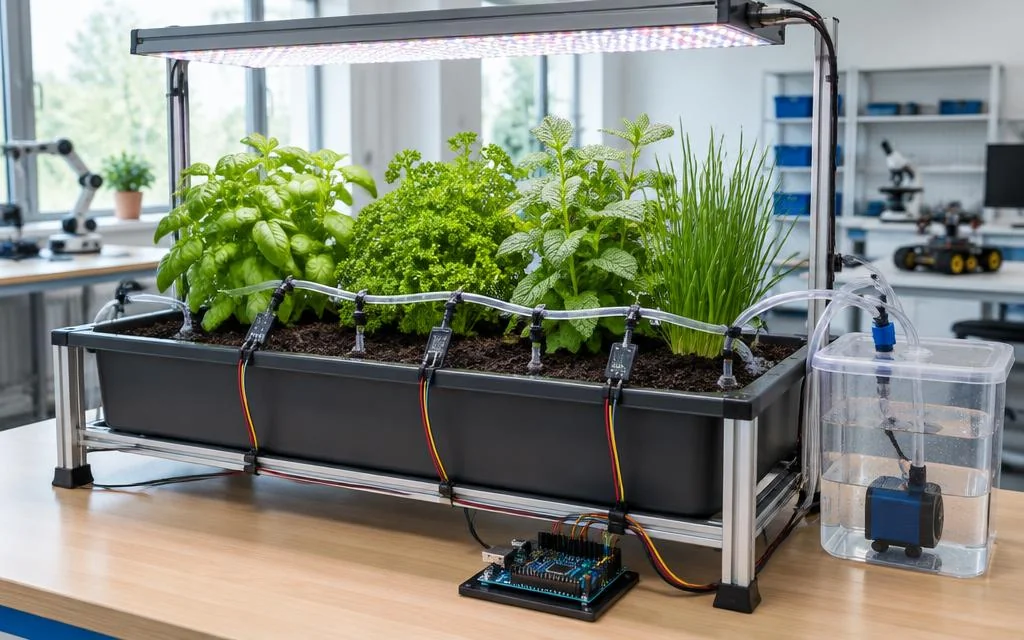
Your irrigation and lighting controller, wired to real soil probes and a pump.
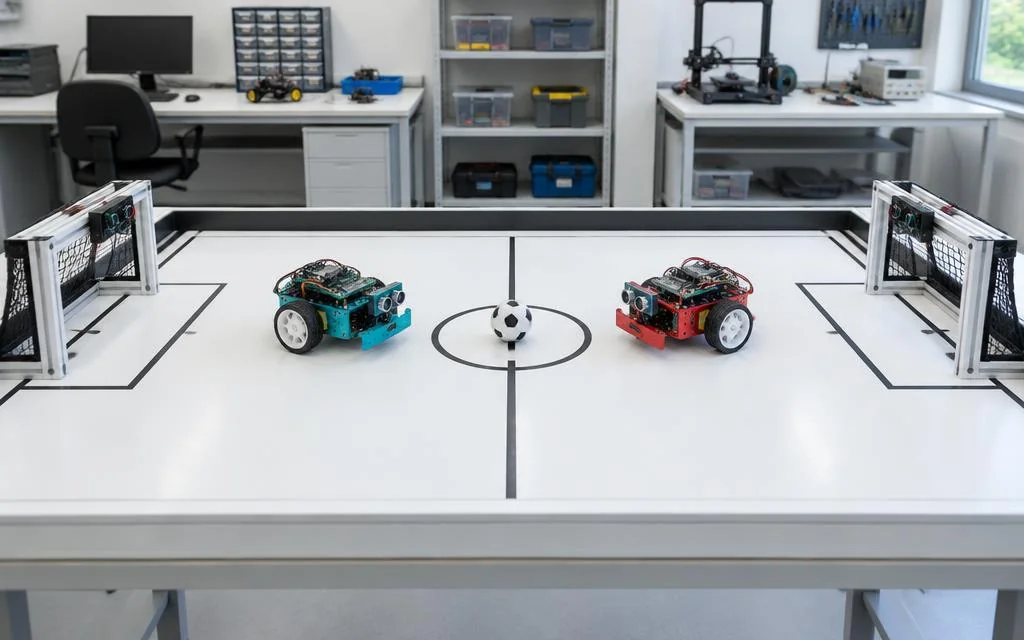
Two seats, two robots, one pitch. IR goals score; a league table follows.
Every run leaves a record: your design, the exact program and its hash, telemetry, video and grade.
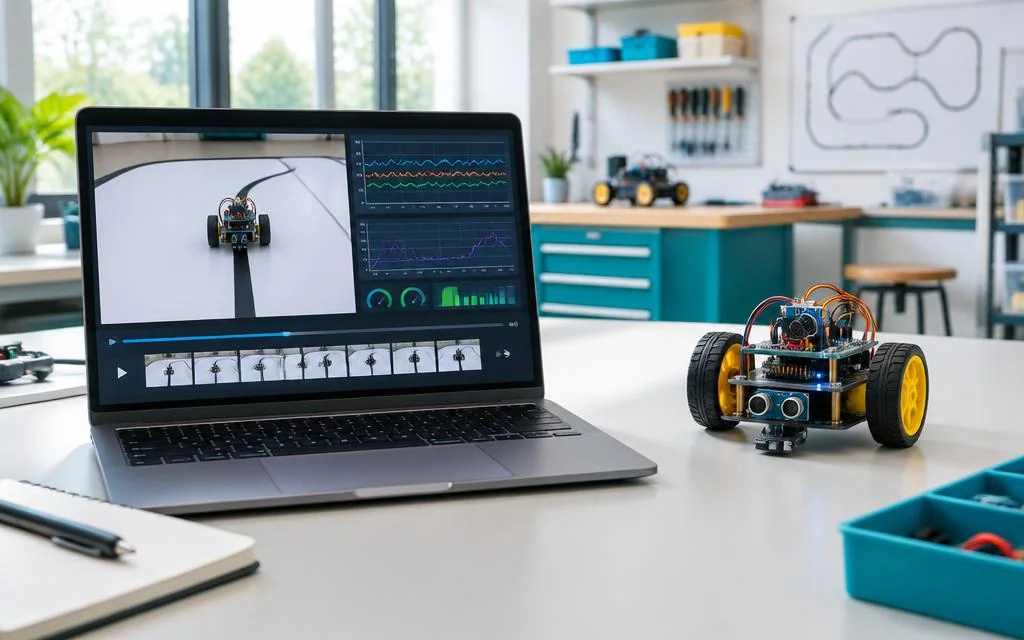
Scrub the video and telemetry together, then load the run back into MoonVerse as a ghost.
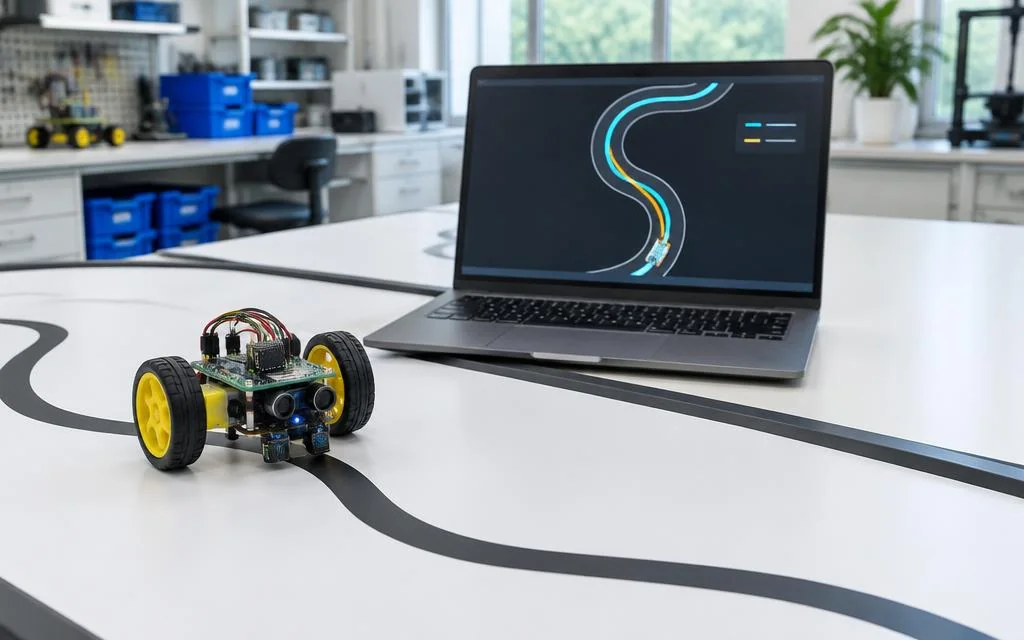
Where the robot left the simulated path, and why. MoonVerse learns from it too.
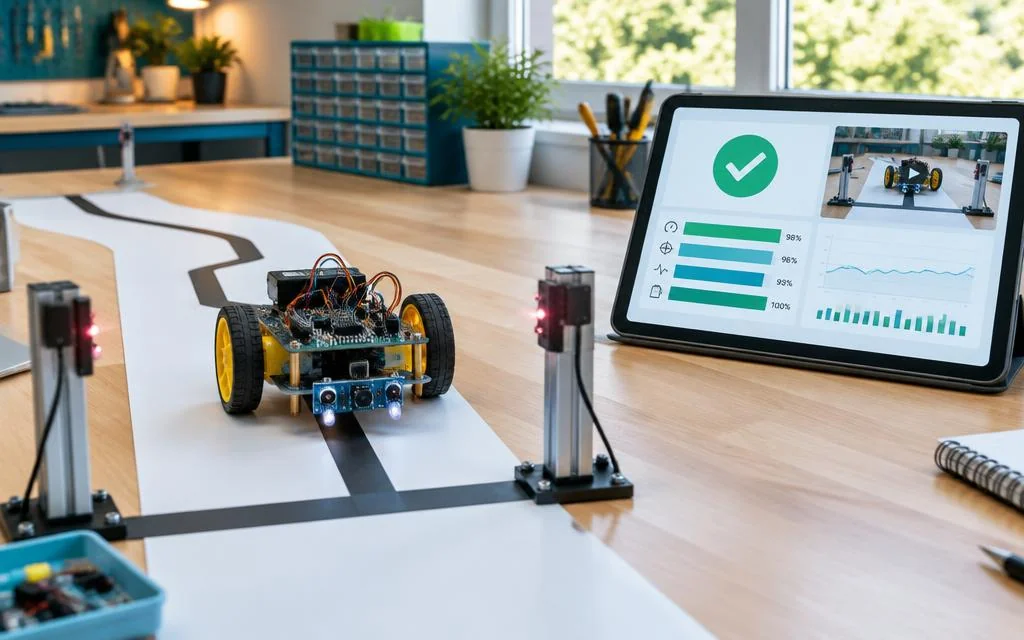
Your grade reflects what happened on the real robot, not only on screen.
Design as authored | Program and hash | Bay and role map | Telemetry and pose | Events and console | Recordings and score | Sim-to-real difference
One flagship lab today, growing into new bay types and, over time, sites beyond Earth.
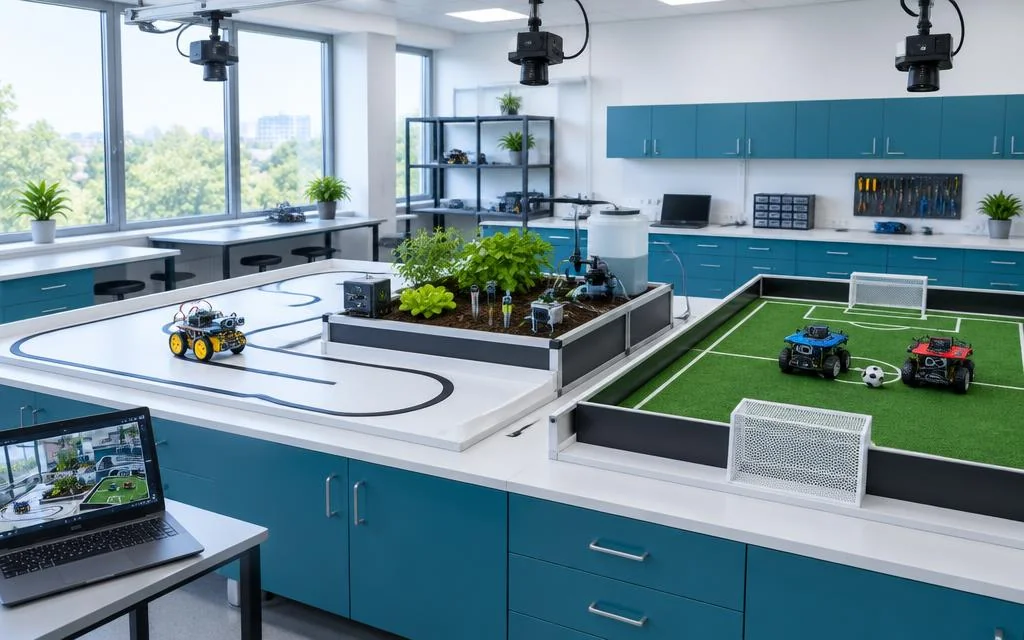
Three bay types at launch, 30 or more bays within a year, booked and watched remotely.
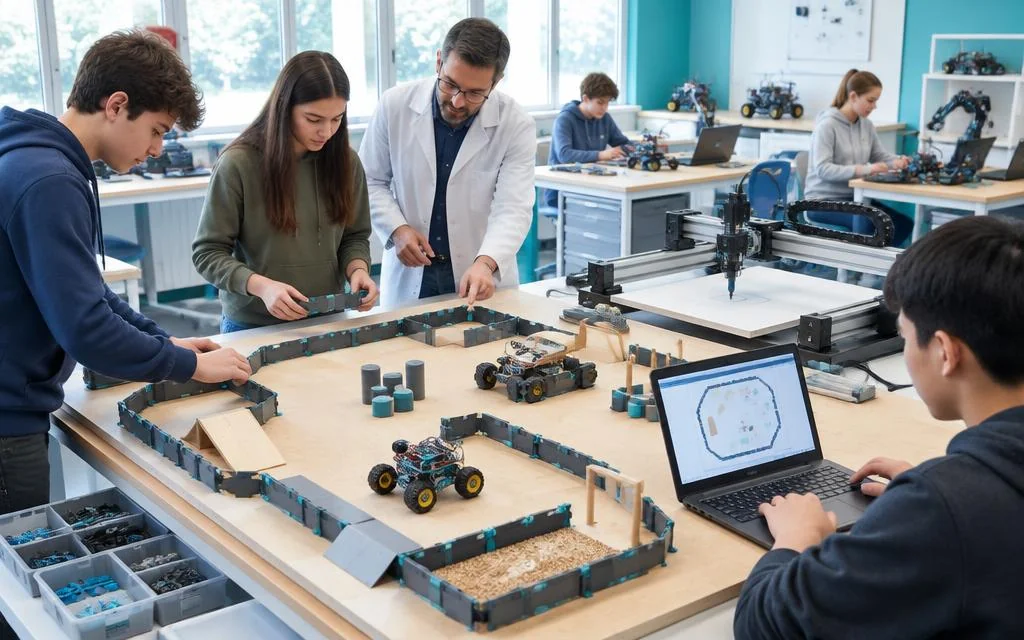
Student-designed arenas, classroom mode and new bay types. Still one lab.
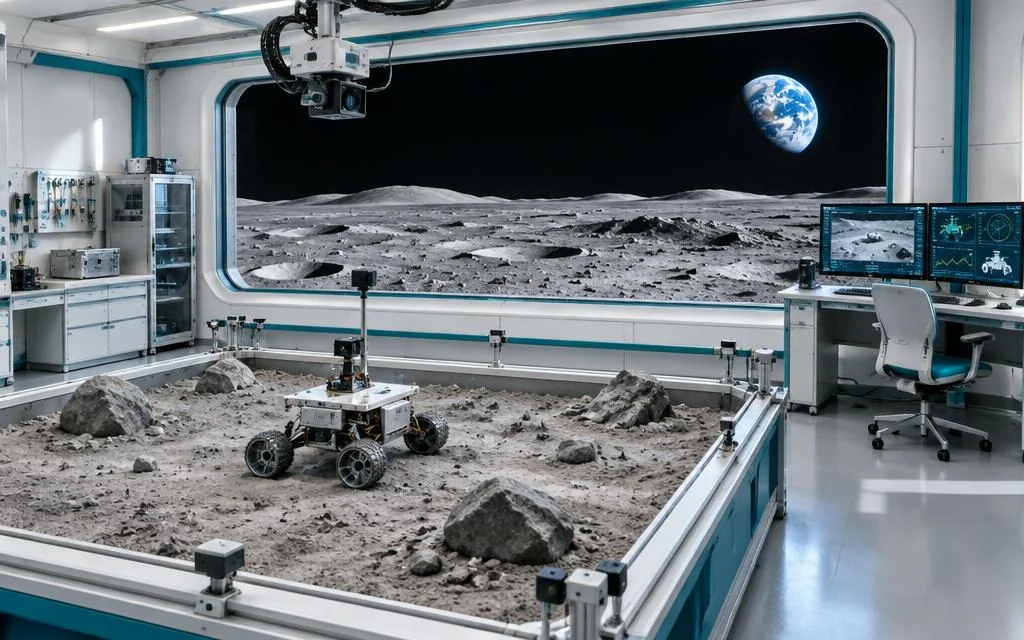
Bays in the deep ocean, in orbit and on the Moon. Your design is tested where you could never go.
Build in MoonTinker, simulate in MoonVerse, deploy on MoonKits, and run it for real here.
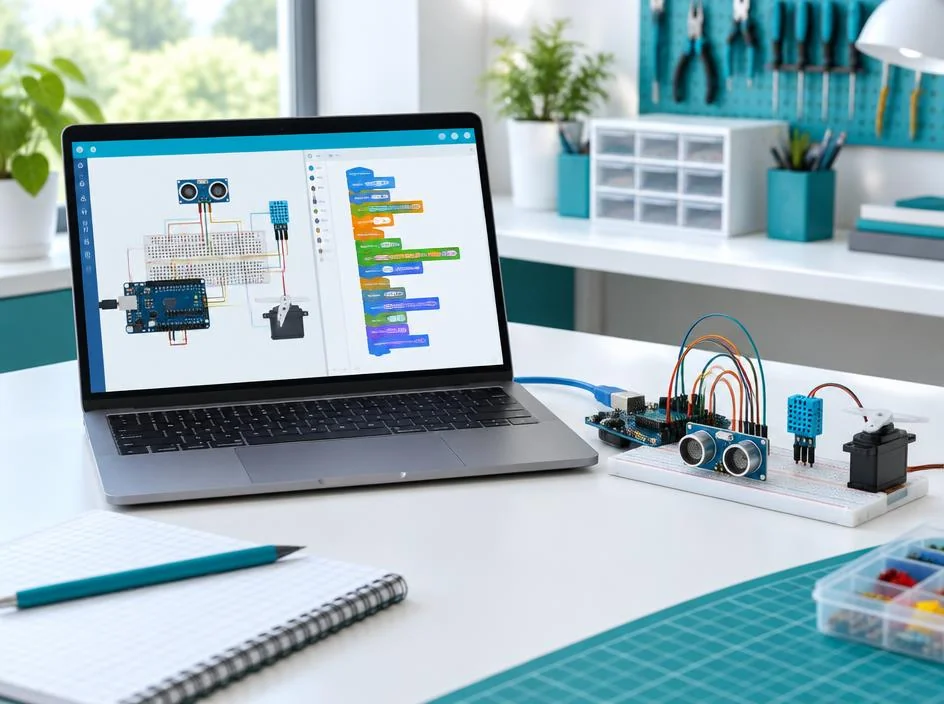
Code. Design. Simulate.
Circuit and coding environment for components, sensors and control logic.
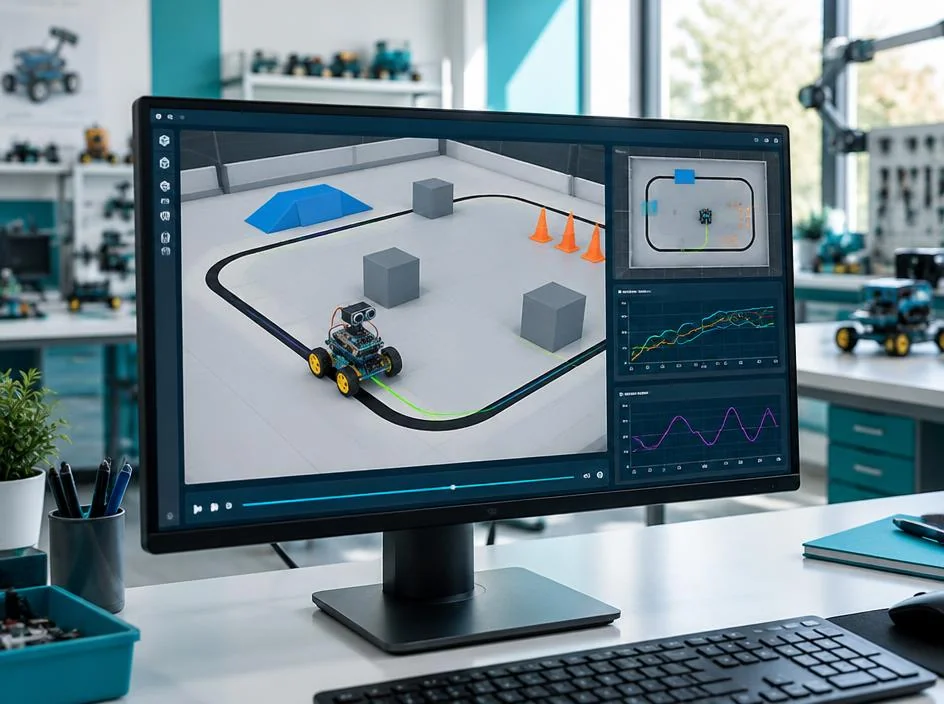
System-level modeling and simulation.
Model systems and test behavior before a real robot is involved.
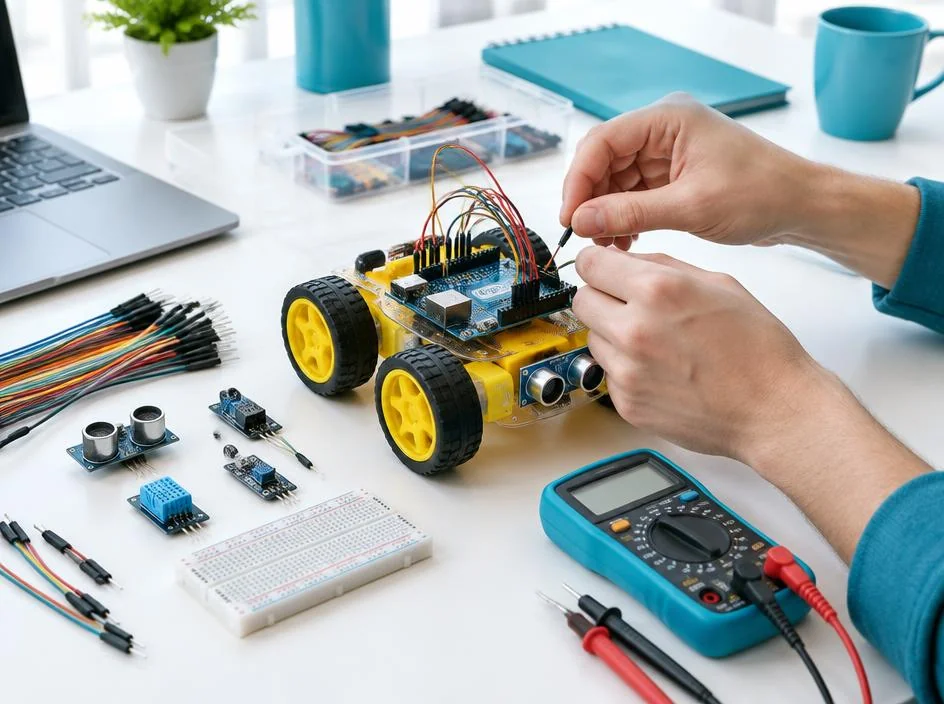
Calibrate. Deploy. Validate.
Wire, calibrate, test and debug robotics and AI projects on real hardware.
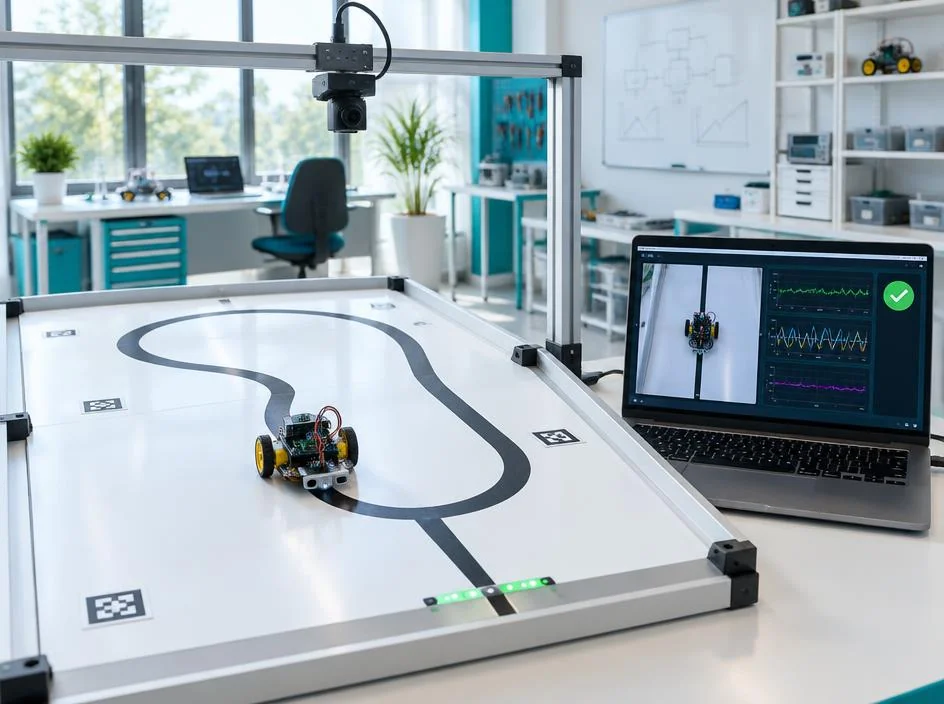
Run it for real.
Runs your proven program on a real robot and returns the recording, data and grade.
Prove it in MoonVerse. Then run it for real.
Every bay takes the program you proved in MoonVerse, unchanged.
Open MoonVerse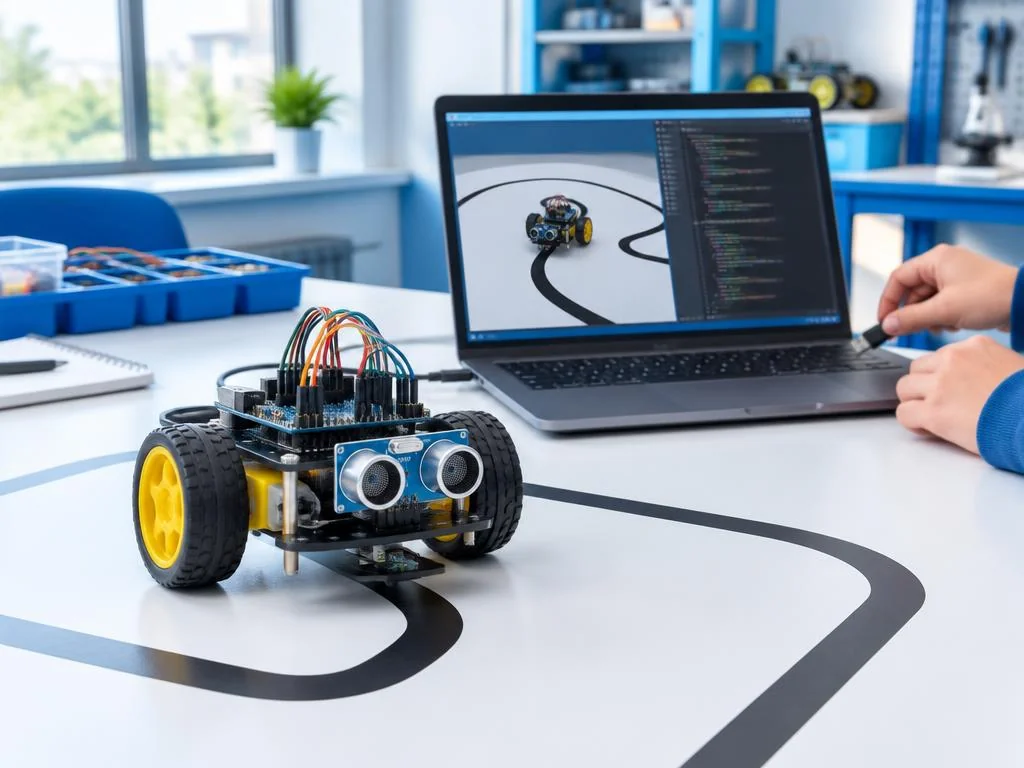
©️ Copyright, Moonpreneur Inc.
691 S Milpitas Blvd, STE 217 Milpitas CA 95035, USA
